Research
Federated Learning for Distributed Robotic Fleets
Motivation
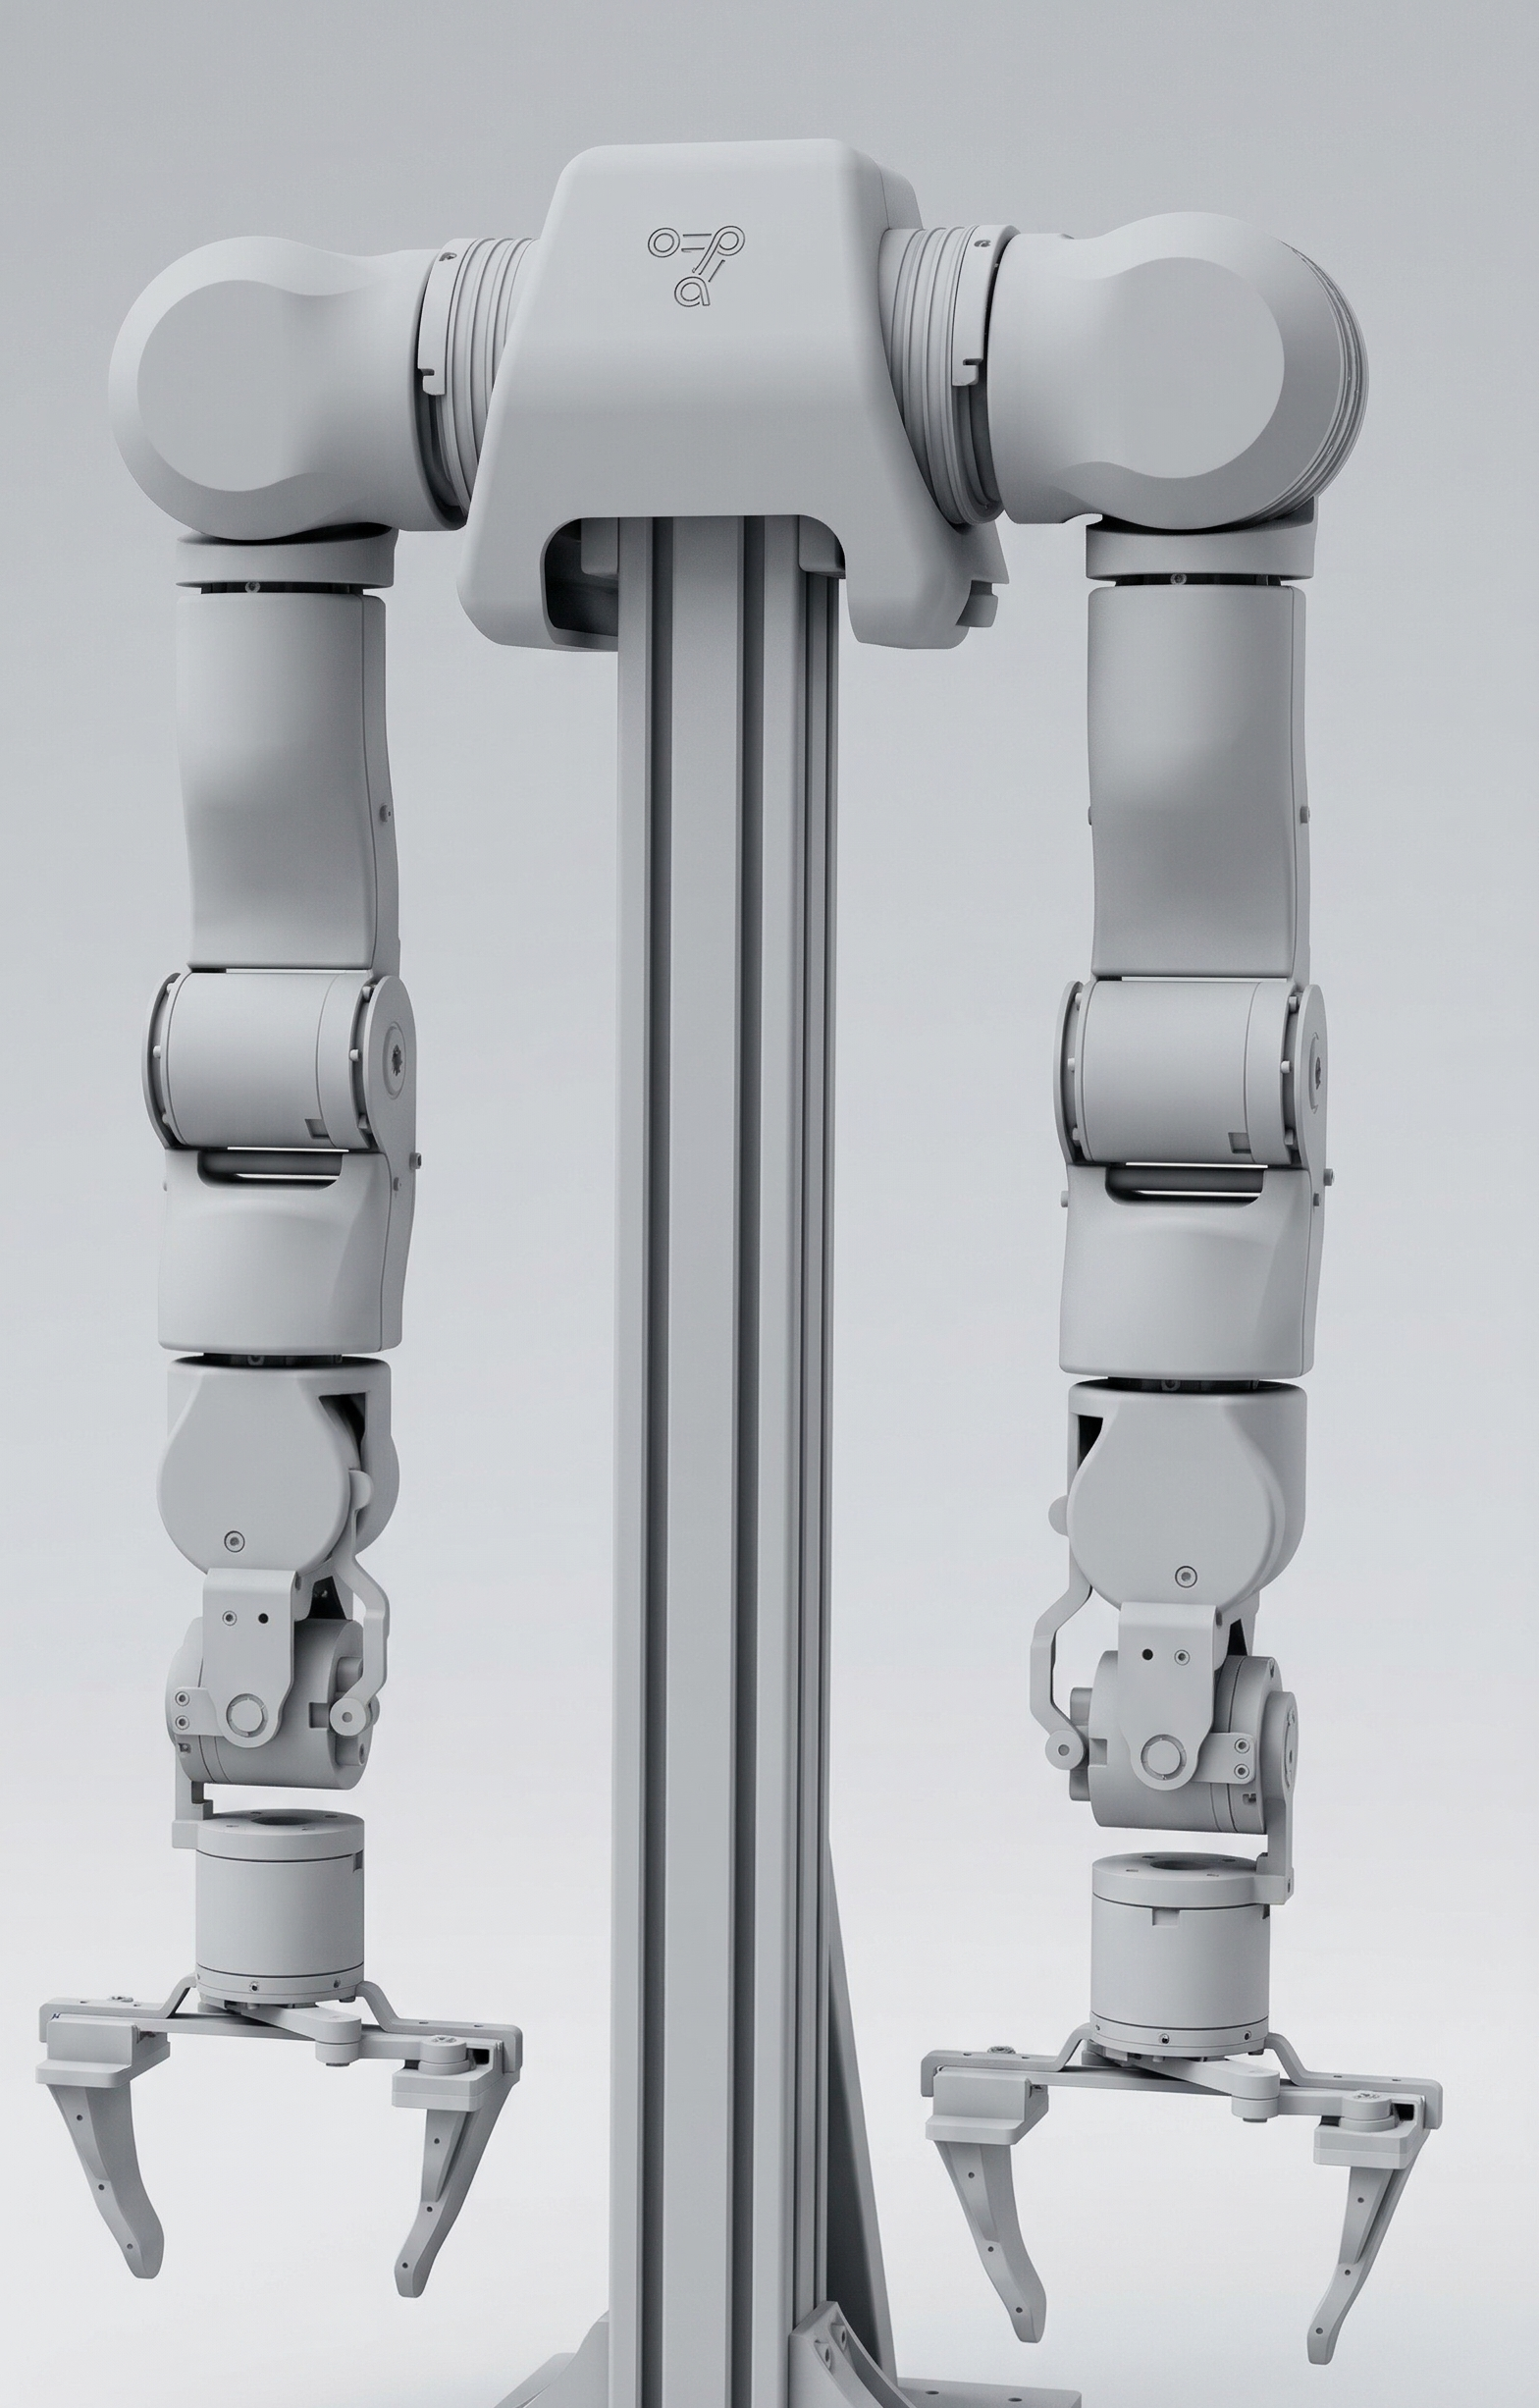
Distributed robotic fleets possess enormous potential for gathering diverse interaction data but face significant privacy and bandwidth challenges when centralizing raw data. Federated learning approaches offer solutions that enable decentralized data processing and collaborative model improvement, significantly benefiting distributed robotic systems. Ensuring privacy, efficient bandwidth use, and collective learning from diverse environments are essential for scalable robotic fleet management.
Research Direction
Our research develops decentralized training frameworks using federated learning protocols, allowing distributed robotic systems to collaboratively refine global models without centralizing raw sensor data. We aim to optimize privacy preservation, bandwidth efficiency, and collective intelligence, enabling robotic fleets to leverage diverse environmental data effectively. Ultimately, our goal is to create robust, collectively intelligent systems through decentralized learning.