Research
Cross-Embodiment Robotic Generalization
Motivation
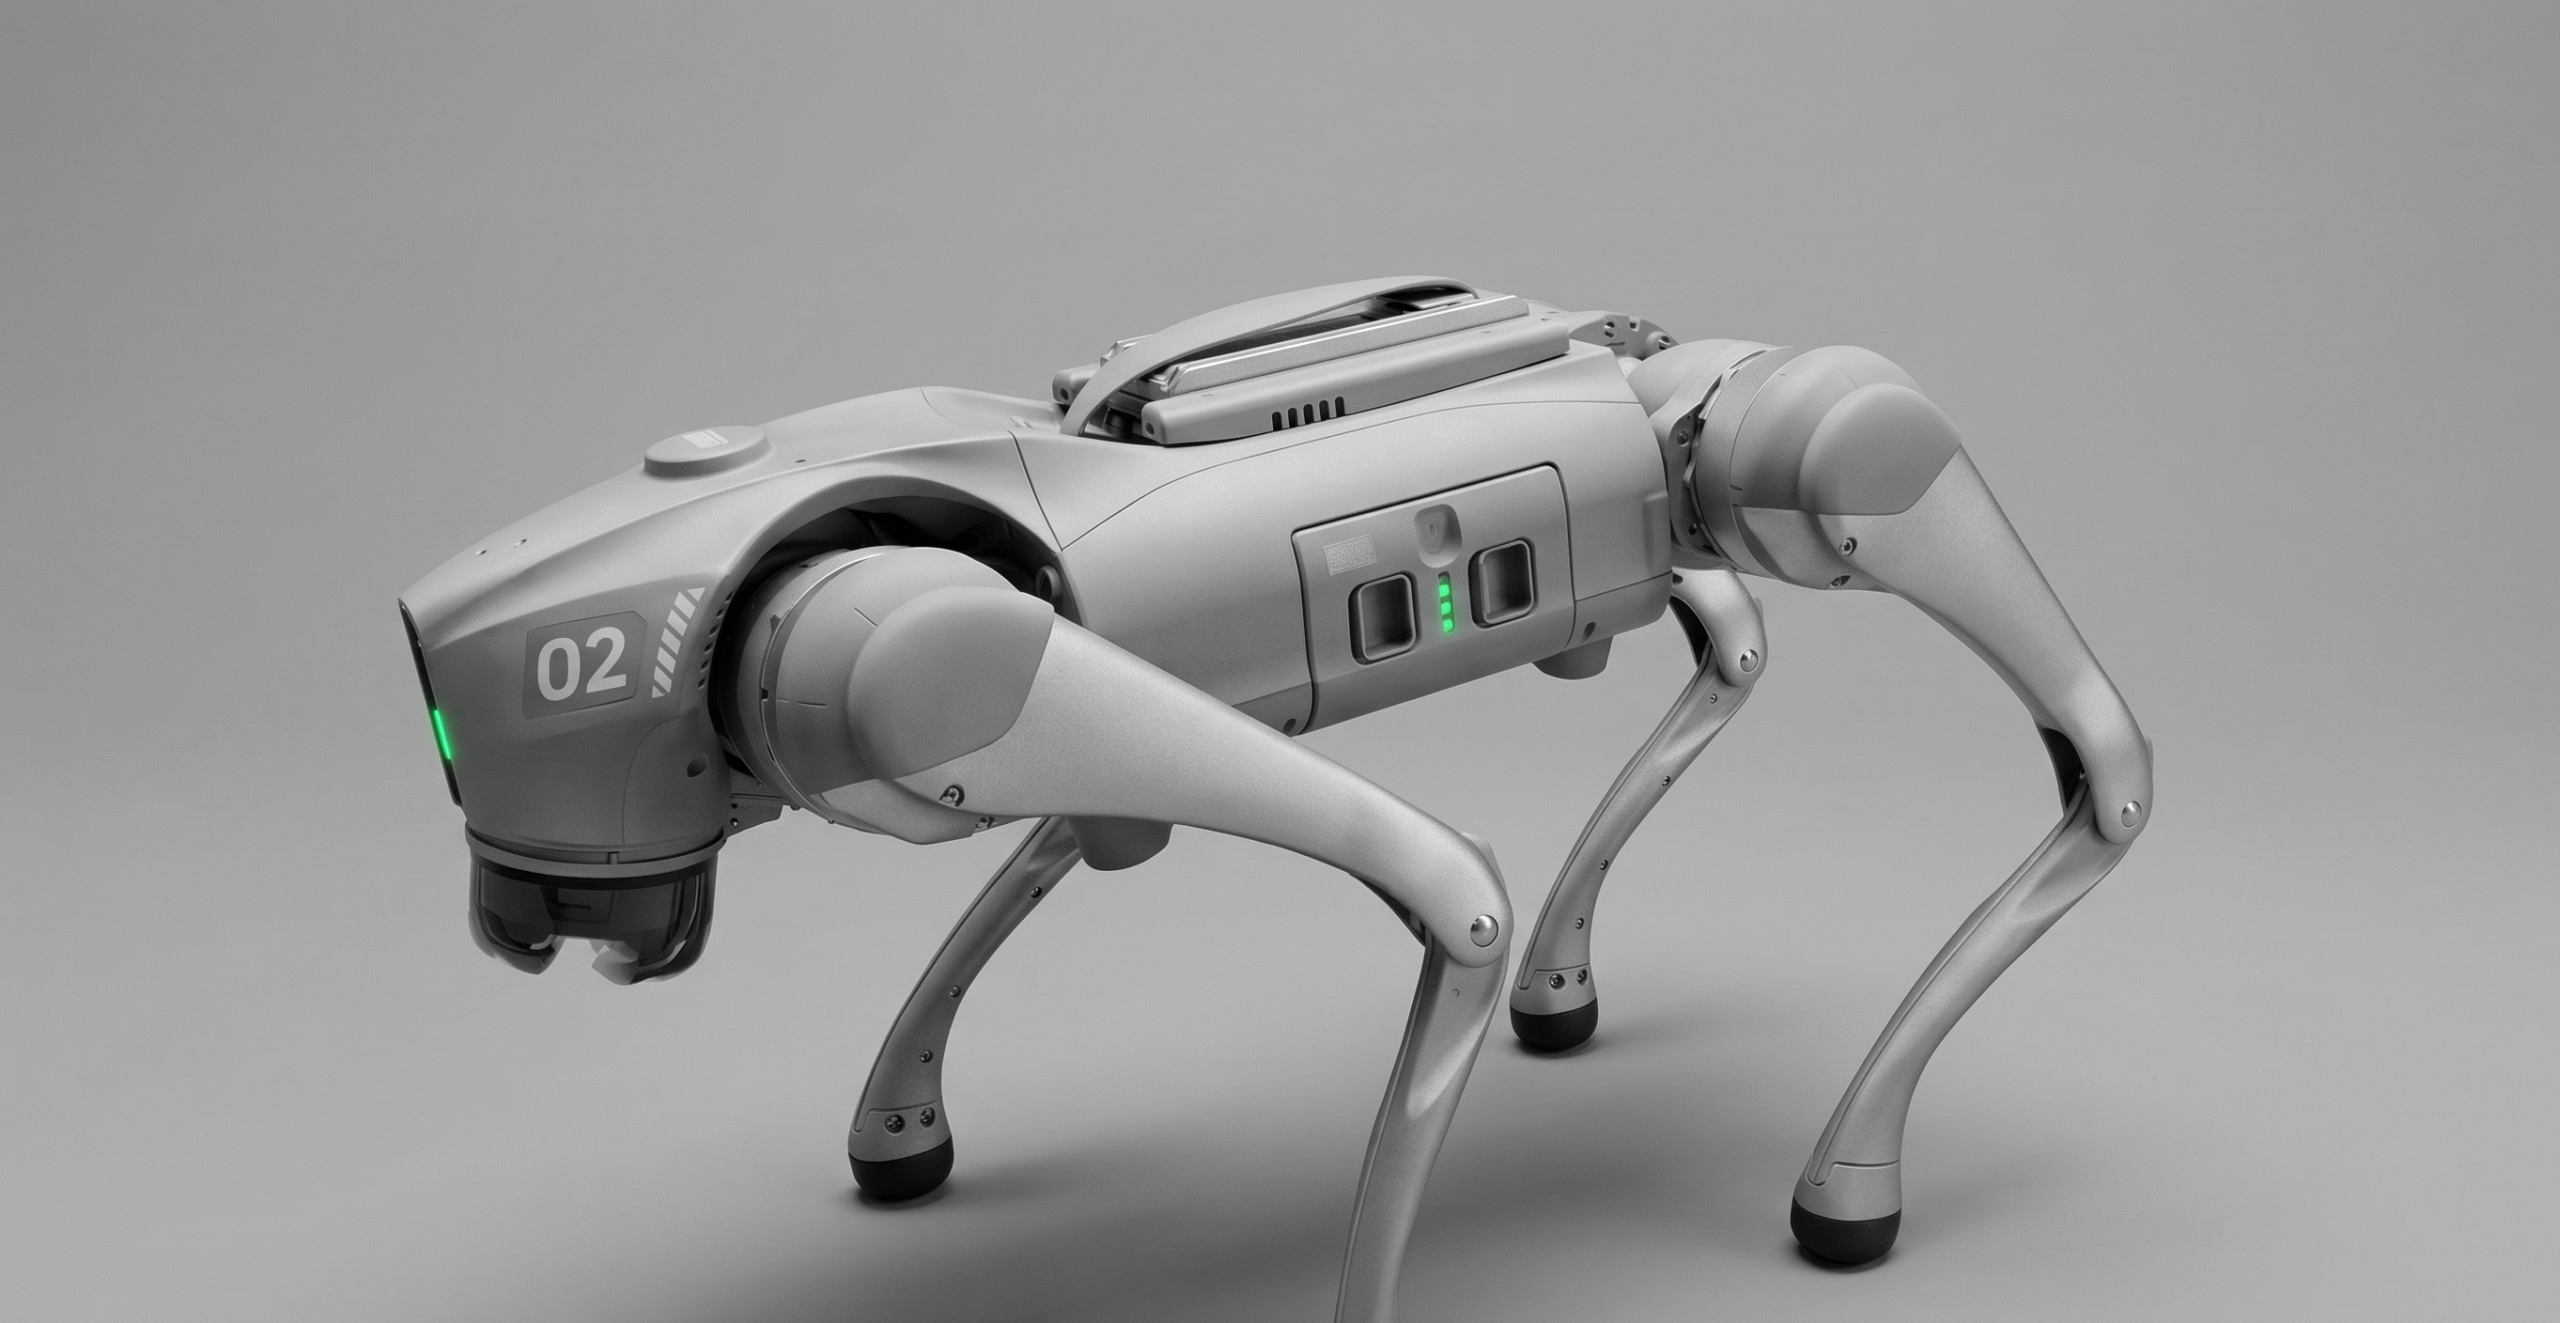
Robotic intelligence currently suffers from limited transferability between different hardware platforms, significantly constraining practical deployments. The development of models capable of transferring learned behaviors across varied robotic embodiments, such as industrial arms and humanoids, is imperative for scalable and widely applicable robotic solutions. Achieving hardware-agnostic intelligence could revolutionize the efficiency and adaptability of robotic systems.
Research Direction
Our work focuses on building transferable foundation models that leverage shared representations to generalize knowledge across diverse robotic morphologies. By emphasizing cross-embodiment scalability, we aim to facilitate seamless adaptation and efficient transfer of robotic behaviors, independent of specific hardware designs. Our research seeks to establish foundational principles for universal robotic intelligence.